Naming a sensor is not the same as counting it
A sensor line on a spec sheet usually names a type of sensing and stops there: "LiDAR" says a robot can range its surroundings, not how many units do it or what processes what they return. Read across AGIBOT's own catalogue, and the detail behind it swings from a counted list to a single word, "included" or "not included". Among the humanoids, the G2 goes furthest, and reading what it publishes against the two platforms either side of it says more about what perception hardware costs, and what a catalogue chooses to tell you, than any one spec sheet could alone.
- Among the humanoids, only the G2 itemises.
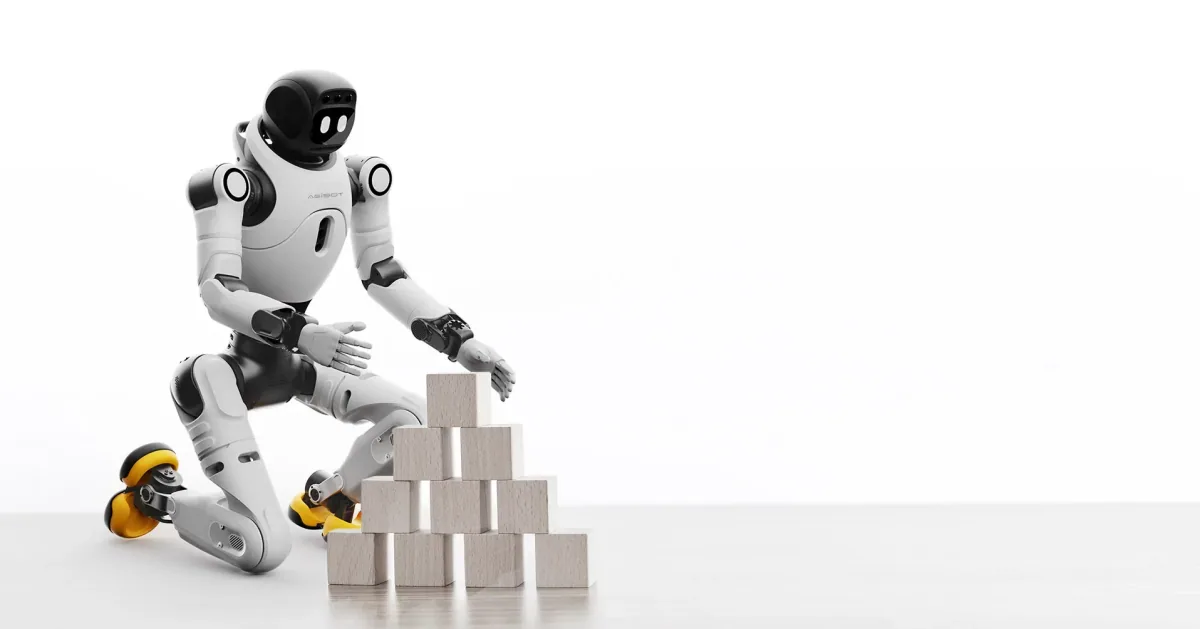
- Its sensors line: two 3D LiDAR units, three fisheye cameras, a binocular camera, three RGB-D cameras, eight ultrasonic sensors, an IMU and a four-microphone array. Three types also have a counted row, 3D LiDAR (2), fisheye camera (3) and RGB-D camera (3), all processed on a HUIXI R1 board rated at 500 TOPS at INT8. The G2 is a wheeled humanoid, not a legged one, exactly the configuration that has to place itself on a floor plan and route around obstacles without a person walking beside it. No other humanoid's table gives a sensor type its own counted row, rather than folding any count into one descriptive line.
- The X2 Ultra names the same kinds of sensing and stops at the type.
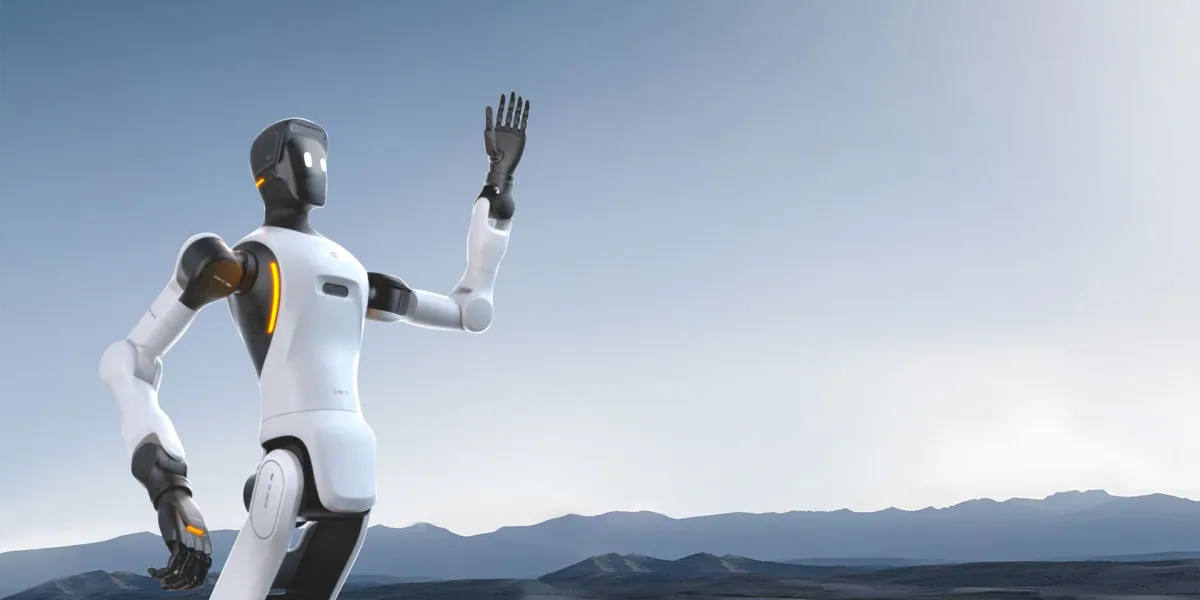
- Its own listing reads 3D LiDAR, RGB-D, front stereo RGB, rear RGB and touch sensors, on an NVIDIA Orin NX board rated at 157 TOPS. The G2's LiDAR, RGB-D and binocular cameras have a rough match here; its fisheye cameras, ultrasonic sensors, IMU and microphone array do not. What is missing is the number: the listing says the Ultra carries LiDAR, not how many units, and RGB-D, not how many cameras. Reading the G2's counted rows against the Ultra's uncounted ones is the more honest comparison, offered here as a second data point in the same catalogue, not as a claim that one outperforms the other on coverage, which a modality name alone cannot show.
- The X2 Basic publishes the clearest answer of the three: none.
- Its own table marks the 3D LiDAR and RGB-D camera rows "not equipped", a stated zero rather than silence on the row. A platform that says nothing about a sensor type could mean it carries none, or could mean nobody filled the row in, and a buyer cannot tell which from outside. AGIBOT removes that ambiguity for the Basic specifically, the same discipline the G2 applies at the other end of the range, in the opposite direction: state the number, even when it is zero.
- Even the fullest itemisation among the humanoids stops at counts.
- The G2's sensors line gives a number for every type it names, and three types get a row of their own, but this table gives no range, field of view or resolution for any of them, and does not say which board processes which. The most itemised humanoid in the range still leaves this table short of a genuine bill of materials, and naming that gap is more useful than assuming the counts stand in for the rest.
None of this argues for choosing the G2 over the other two. A wheeled humanoid, a sensed one and an unsensed one solve different problems, and perception hardware is only worth its cost if the job needs that much sensing. What it argues for is asking the same three questions of any platform's sensor line before "autonomous" gets treated as answered: what kind of sensor, how many units, and what board processes what they return. The G2's own table answers the first two for every sensor it lists; the X2 Ultra answers the first question only; the X2 Basic answers neither, because for LiDAR and RGB-D it has nothing to count. Ask for the missing number directly, rather than reading a modality name as if it already were one.
We can walk through what a full perception count would need to add up to for a specific site, before a platform gets chosen on the strength of its sensor line alone.