Skip to content
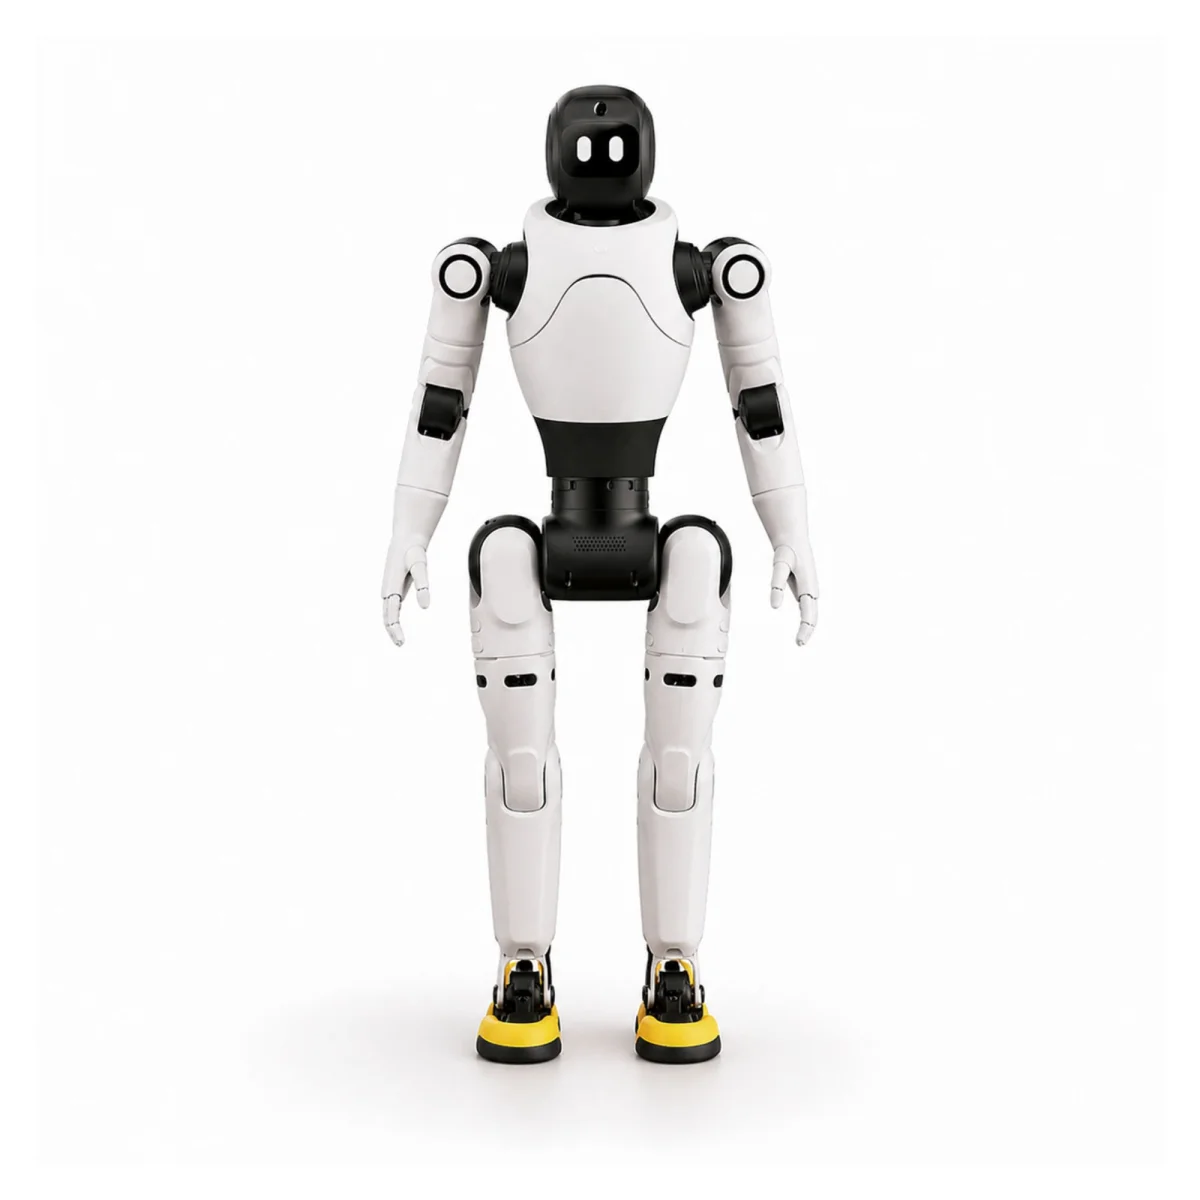
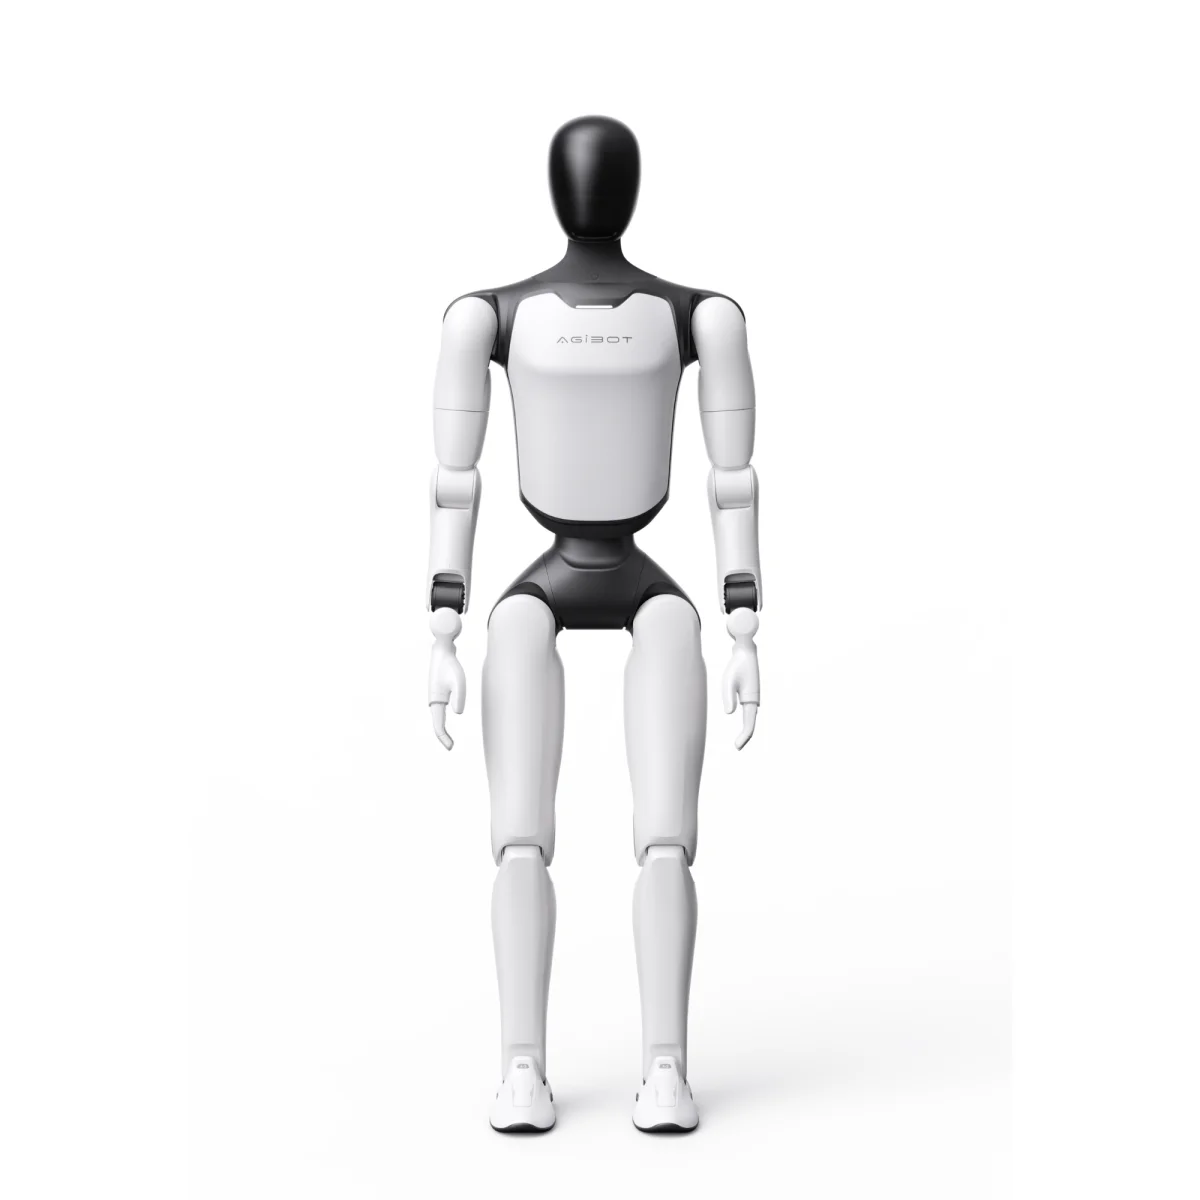
The AGIBOT X2 Ultra humanoid robot standing with its arms held slightly away from its body, front view, with yellow hands and yellow soles against a plain ground.

Humanoid robots

AGIBOT X2 Ultra

The X2 that finds the part rather than being handed it: 3D LiDAR and RGB-D vision let it locate objects and move through a space nobody mapped by hand. It lifts 3 kg per arm, walks at 2 m/s and returns to its own docking station to charge, so nobody has to plug it in mid-shift. Two hours of runtime, 30 active joints, and the same AimDK_X2 SDK as the Basic.

Manufacturer: AGIBOT

Also available for rental

Request a quote

Tell us what the robot needs to do. You get a configuration, a price and a delivery date.

Request a quote

What it does

Photography and published figures from AGIBOT, the manufacturer of this model.

Multimodal interaction

Vision, voice, touch and an expressive face are handled together: it greets first, and a pat on the head gets a spoken reply. AGIBOT does not publish a count of the facial animations available.

Lifelike movement

Between 25 and 30 degrees of freedom, with dancing and cycling among the manufacturer's published locomotion modes.

Autonomous tasks

The Ultra trim navigates on its own, avoids obstacles as they appear and returns to its charging station when the battery runs low.

Diagrams from the manufacturer

AGIBOT publishes these drawings in English. We show them exactly as published.

  • Technical diagram 1 of 6 for the AGIBOT X2 Ultra, published by the manufacturer
  • Technical diagram 2 of 6 for the AGIBOT X2 Ultra, published by the manufacturer
  • Technical diagram 3 of 6 for the AGIBOT X2 Ultra, published by the manufacturer
  • Technical diagram 4 of 6 for the AGIBOT X2 Ultra, published by the manufacturer
  • Technical diagram 5 of 6 for the AGIBOT X2 Ultra, published by the manufacturer
  • Technical diagram 6 of 6 for the AGIBOT X2 Ultra, published by the manufacturer

Software and SDK

Manufacturer product page
www.agibot.com/products/X2
Licence
Mulan PSL v2

Permissive licence: you may build on this commercially, provided you keep the licence and notices. Verified against the repository, not a marketing page.
Technical specification

Technical specification
HeightApprox. 131 cm
Dimensions generic1310 (H) × 460 (W) × 210 (D) mm
WeightApprox. 39 kg
Degrees of freedom30 active DoF
Arm reach558 mm (without end effector)
Sensors3D LiDAR, RGB-D, front stereo RGB, rear RGB, touch sensors
Operating temperature range-10 °C to 40 °C
Autonomous charging dockYes (dedicated docking station)
SDKAimDK_X2 (Python & C++)
Speed2 m/s
Runtime2 h
Payload per arm3 kg
Neck DoF1
DoF per arm7
Waist DoF3
DoF per leg6
Peak joint torque120 Nm
BatteryApprox. 500 Wh
Charging timeUp to 1.5 h
Charging voltage100-220 V
Charger output54.6 V / 10 A
Compute platform2 × RK3588
High-performance compute boardNVIDIA Orin NX, 157 TOPS
Expansion ports2 × USB Type-A, 2 × USB Type-C
LAN ports2 × RJ45
Power interfaces1 × 12 V / 3 A, 1 × 48 V / 5 A
Communication interfacesWi-Fi, Bluetooth, 4G/5G
Handheld controllerIncluded
Over-the-air updatesSupported
Mobile appSupported
Customer-side developmentSupported

Where these figures come from: 22 of the 31 rows above are held against the manufacturer's own published parameter tables. The remaining 9 come from the reseller listing this catalogue was built from.

Related products

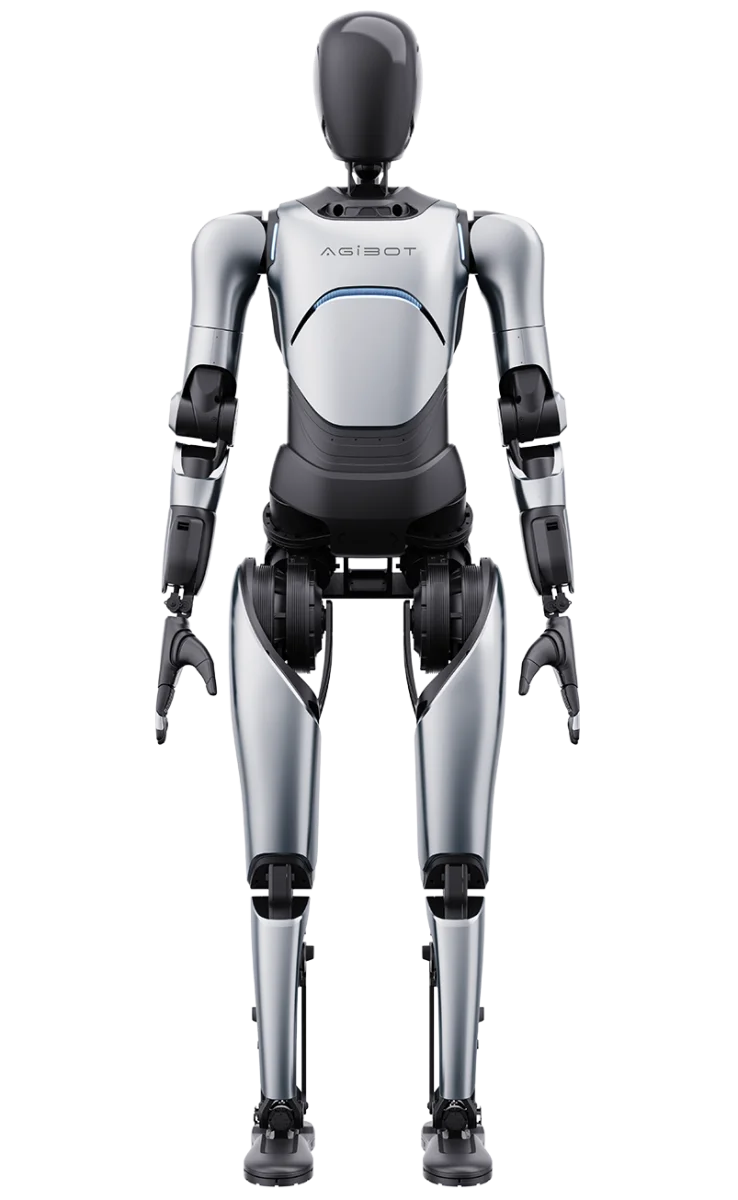
The AGIBOT A2 Ultra humanoid robot seen head on and full length, standing with its arms at its sides, its white shell showing the dark grey joints at the shoulders, elbows and knees.

AGIBOT A2 Ultra

AGIBOT

Works at human height and human reach, so it uses the benches, shelves and controls a room already has instead of needing the space rebuilt around it. Its 40 joints and force sensing suit demonstration, service and research work rather than lifting: about 2 kg per arm at 1.2 m/s. The software stack is AimRT and open source, and the 14.4 Ah pack swaps for a charged one rather than stopping the shift.

View details
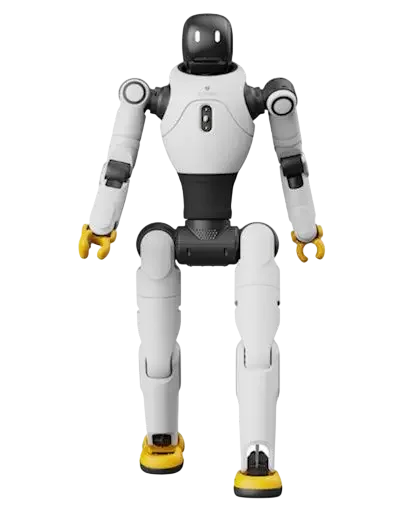
The AGIBOT X2 Basic humanoid robot standing upright on a plain white ground, front view, its white torso and limbs broken by black joint housings and yellow soles.

AGIBOT X2 Basic

AGIBOT

A compact humanoid at 131 cm and 33 kg, small enough to share a room with people and light enough for one person to reposition. It suits a reception, a stand or a teaching lab, where being approachable matters more than payload. The AimDK_X2 SDK ships with it in Python and C++, so a group can write its own behaviour rather than run a fixed demonstration.

View details
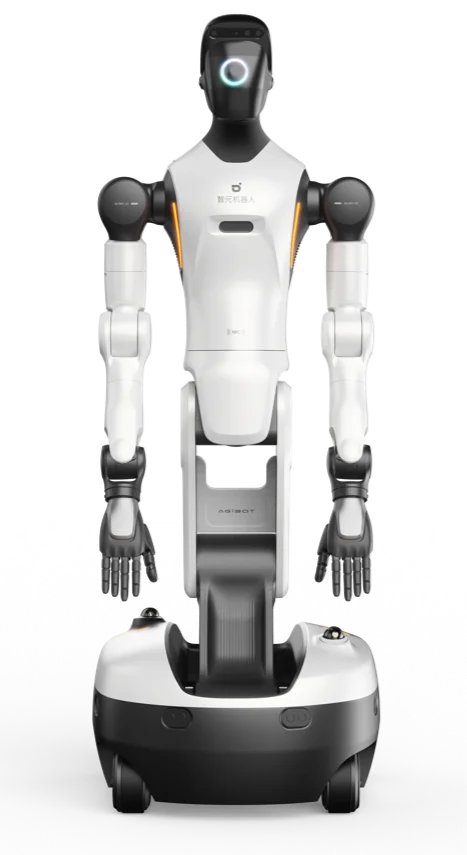
The AGIBOT G2 humanoid robot on its wheeled base, front view, the white upper body and arms rising from a dark rounded chassis instead of legs.

AGIBOT G2

AGIBOT

Built for work where the robot touches things with people nearby: all 26 joints are force-controlled, so contact is regulated rather than resisted. A wheeled base keeps it stable on flat industrial floors, its height adjusts between 1225 and 1795 mm to reach a low bench or a high shelf, and each arm carries 5 kg. Dual hot-swap batteries give about four hours. IP42 keeps out solid objects over 1 mm and dripping water; it is not a dust or washdown rating.

View details
The AGIBOT A3 humanoid robot standing upright on a white ground, front view, its pale shell showing the articulated joints at the hips, knees and shoulders.

AGIBOT A3

AGIBOT

The one to specify for shift work rather than a single demonstration. Batteries hot-swap in ten seconds, runtime reaches ten hours, and more than a hundred units can be coordinated as a group over UWB, so a fleet is a plan rather than an experiment. It walks at 1.8 m/s, runs at 5 m/s and carries 5 kg per arm with an actuator fitted. AGIBOT publishes 92 automotive-grade tests behind it and a design life of up to three years.

View details