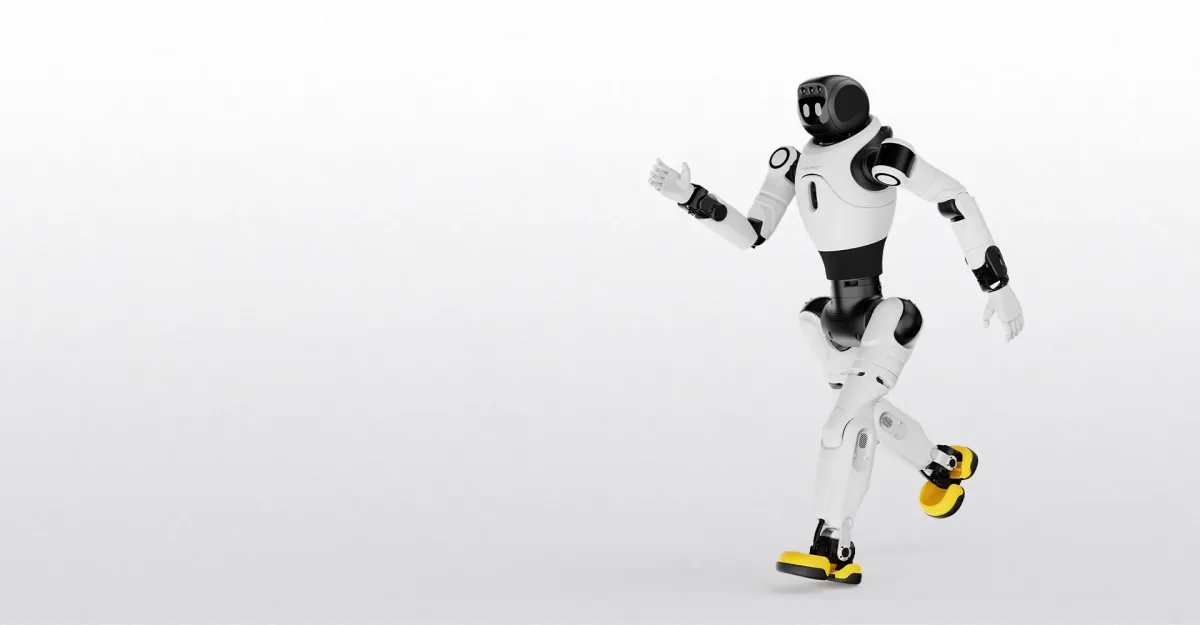
Why 30 degrees of freedom beats 25, and why that is not the reason to choose it
Degrees of freedom is the number every humanoid spec sheet leads with, and on its own it answers a narrower question than it looks like it does.
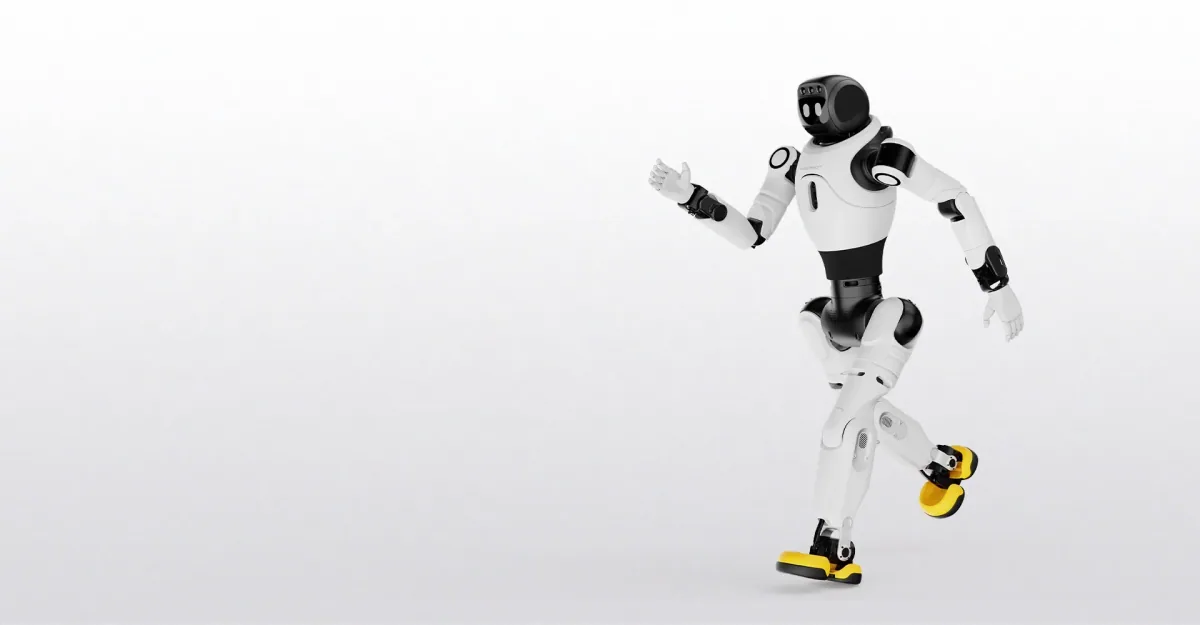
- The X2 Basic carries 25 active degrees of freedom; the X2 Ultra carries 30.
- Five more joints sounds like five more capability, and in a narrow sense it is: more axes of movement, finer control over a given pose. But joint count describes how the machine moves, not what it knows about the space it is moving in, and those are different questions with different answers on this pair.
- The X2 Ultra ships with 3D LiDAR and an RGB-D camera; the X2 Basic ships with neither, by design, not as an omission.
- That is a line between the two platforms that the joint count does not show. A machine with no depth sensing can still play back a routine of movement, expression and speech composed for it in advance, on a clear patch of floor, and that kind of routine, a greeting or a performance, is the Basic's work. A machine that has to locate a part it was not shown in advance, on a bench that is not always set up the same way, needs to sense the space first, and that is what the Ultra's sensors are for rather than its extra five joints.
- So the DoF figure answers how finely a platform can move, and the sensor line answers whether it knows where to move to.
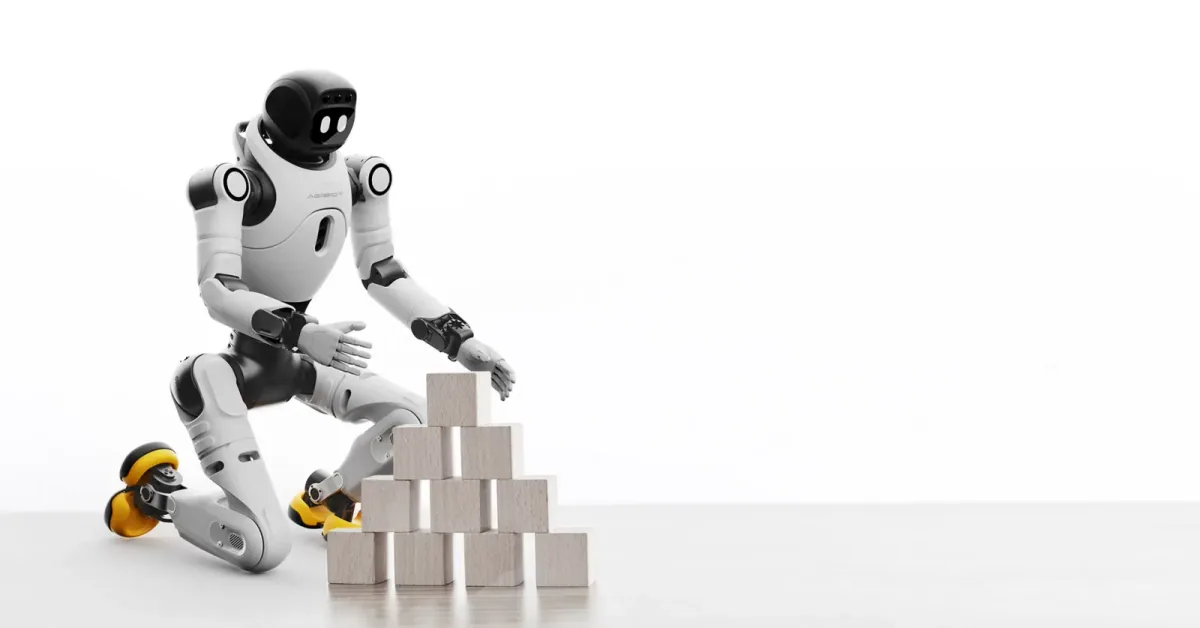
- A pick-and-place cell is not a choice between these two joint counts: AGIBOT's X2 page makes the OmniHand and OmniPicker end effectors compatible with the X2 Ultra only, and its table marks secondary development as not supported on the Basic. The Basic's 25 DoF serve gesture and gait. Of the Ultra's extra five, four are in the arms, two in each, and one is in the neck. A cell where the part's position varies, or where the layout changes between shifts, is a sensing decision before it is a joint-count one, and no amount of extra DoF substitutes for the ability to see where the part actually is.
Reading a DoF figure without asking what the platform can sense is reading half the sheet. The other half is the line that says which sensors are standard and which are Ultra-only, and it is usually the more expensive half to get wrong.