Skip to content
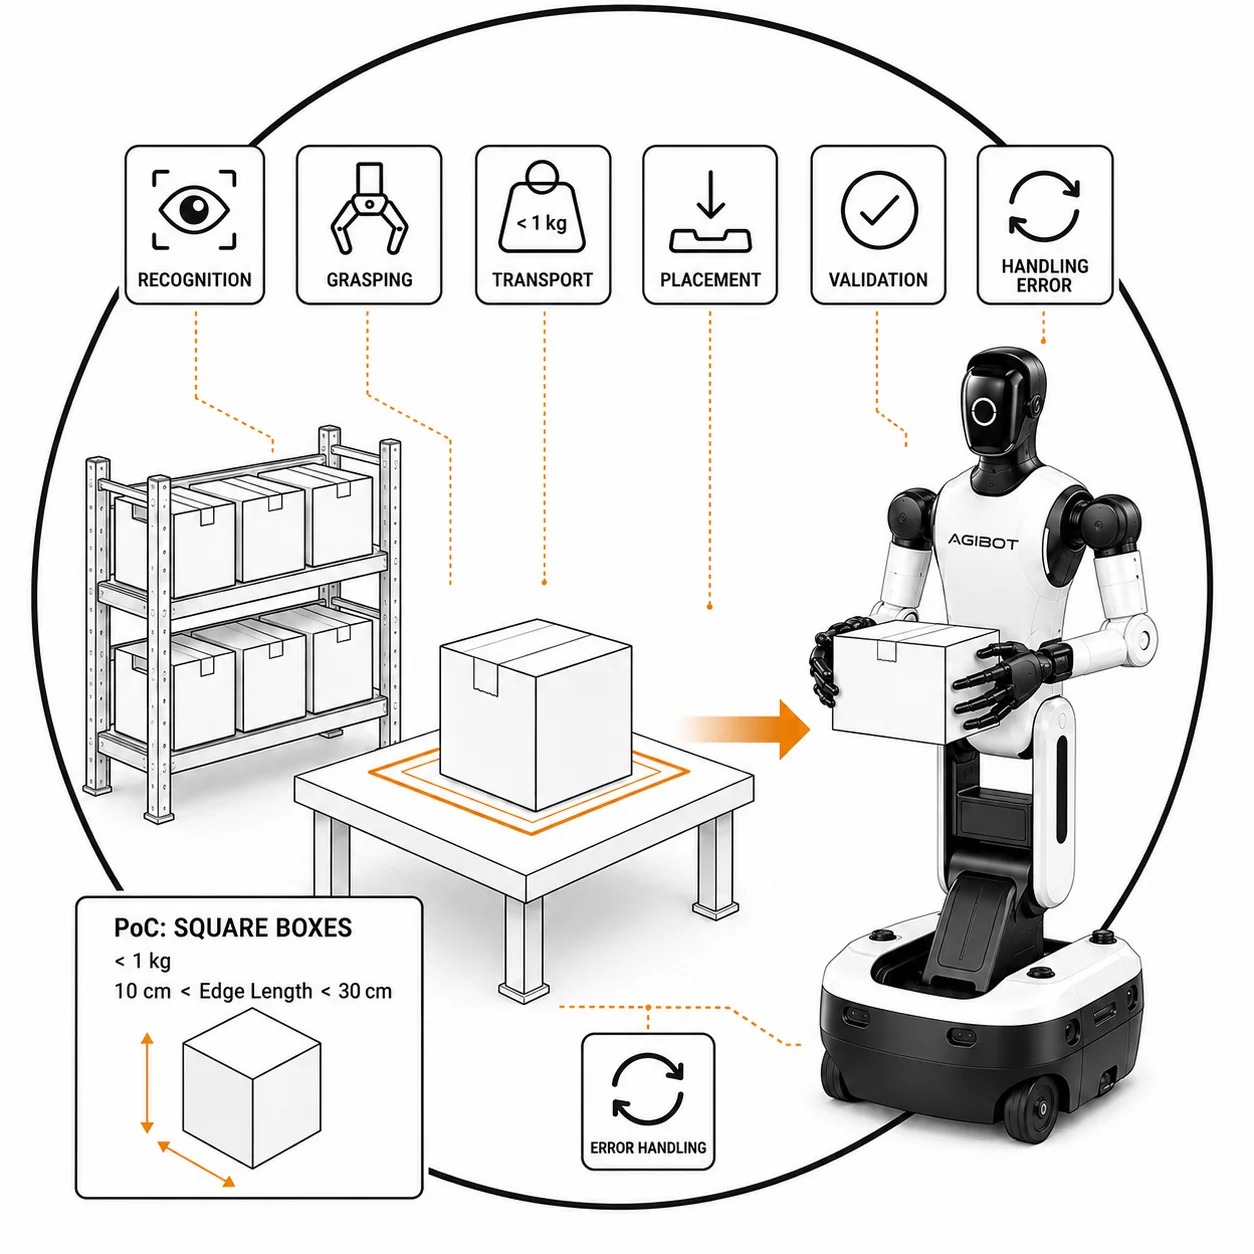
A white humanoid robot on a wheeled base taking a box from a table marked with an orange target square, drawn shelving behind it, under a row of six labelled step icons with a seventh below them and beside a panel describing the size and weight of box the trial covers.

Pick & Place

Picking & Dropping Off Process (hourly rate)

Application engineering for the pick and drop-off cycle itself: grasp selection, approach, placement tolerance and the error handling around them.

Request a quote

Tell us what the robot needs to do. You get a configuration, a price and a delivery date.

Request a quote

What this includes

  • Grasp selection per part, with an approach and retreat that clears the fixture and the neighbours.
  • Placement tolerance measured and then held, including the cases where the target is not empty.
  • A cycle-time breakdown, so you can see where the seconds go and what is worth optimising.
  • Error handling and restart: a dropped part, a missed grasp, an aborted job.

Related products

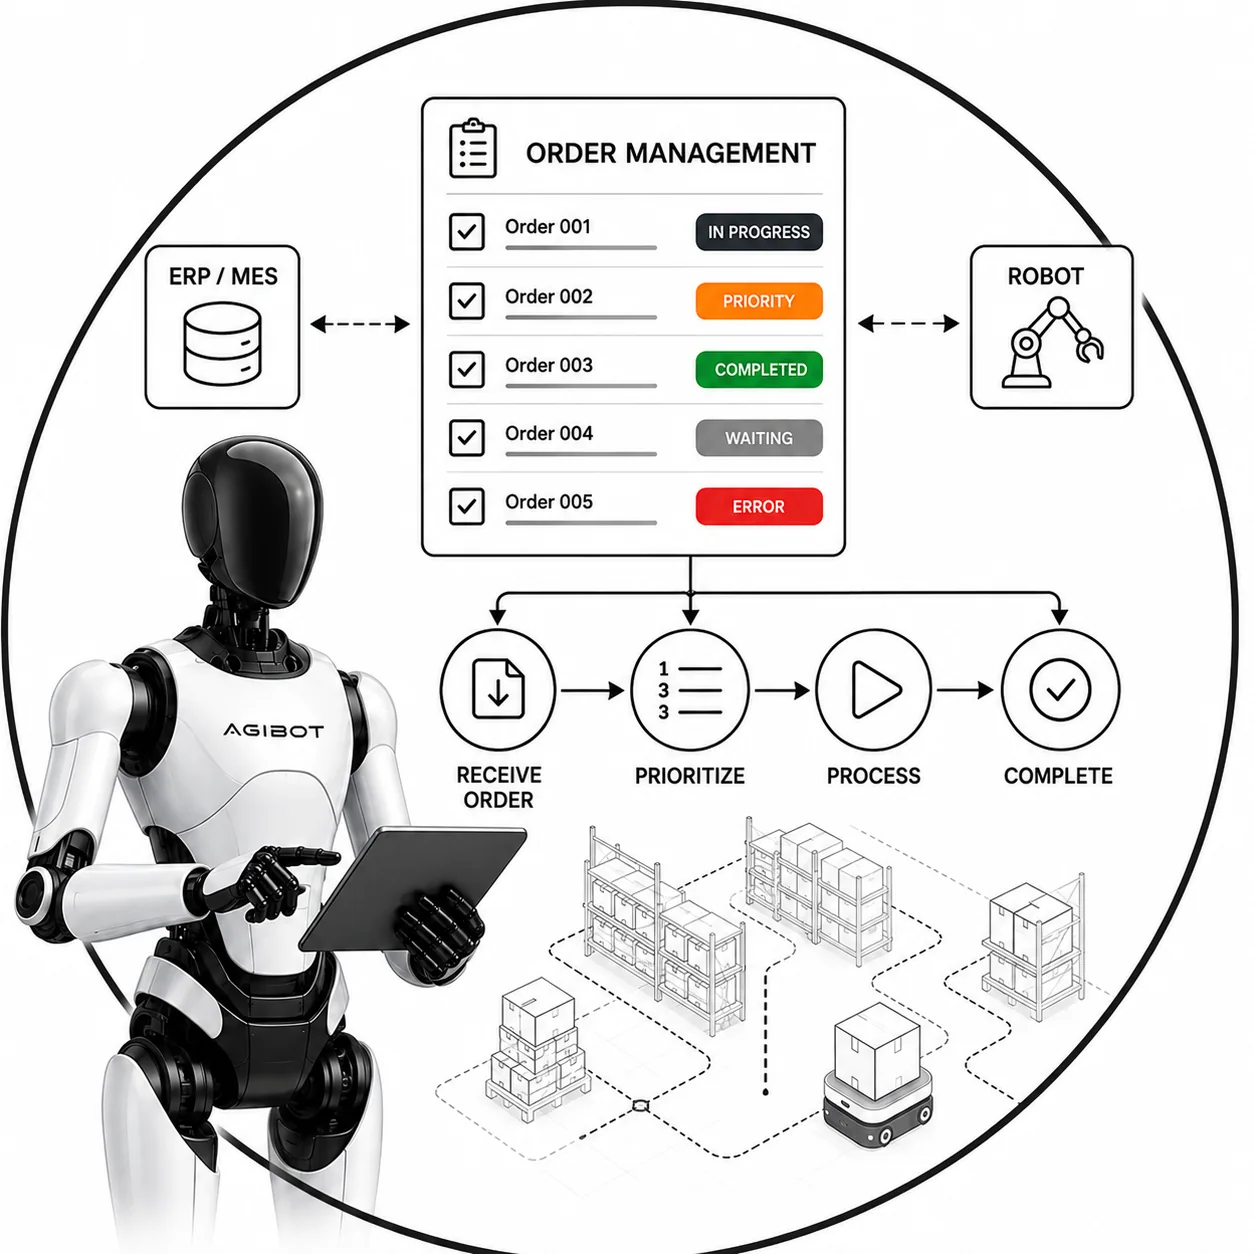
A white humanoid robot holding a tablet in one hand and pointing at it with the other, beside a line-drawn order panel of five numbered rows with coloured status badges, flanked by boxes for the business system and the robot and a drawn warehouse below.

Order Management (hourly rate)

Order-management software for robot pick-and-place: it takes jobs from your system, sequences them and hands the robot a queue it can actually execute.

View details
A white humanoid robot on a wheeled base, pointing into an isometric line drawing of a warehouse marked with location pins, one of them highlighted over a hatched pick area, with small framed icons at the corners.

Mapping (hourly rate)

Mapping of the working area a robot will operate in, delivered as the map layer that the navigation stack and the picking process both depend on.

View details
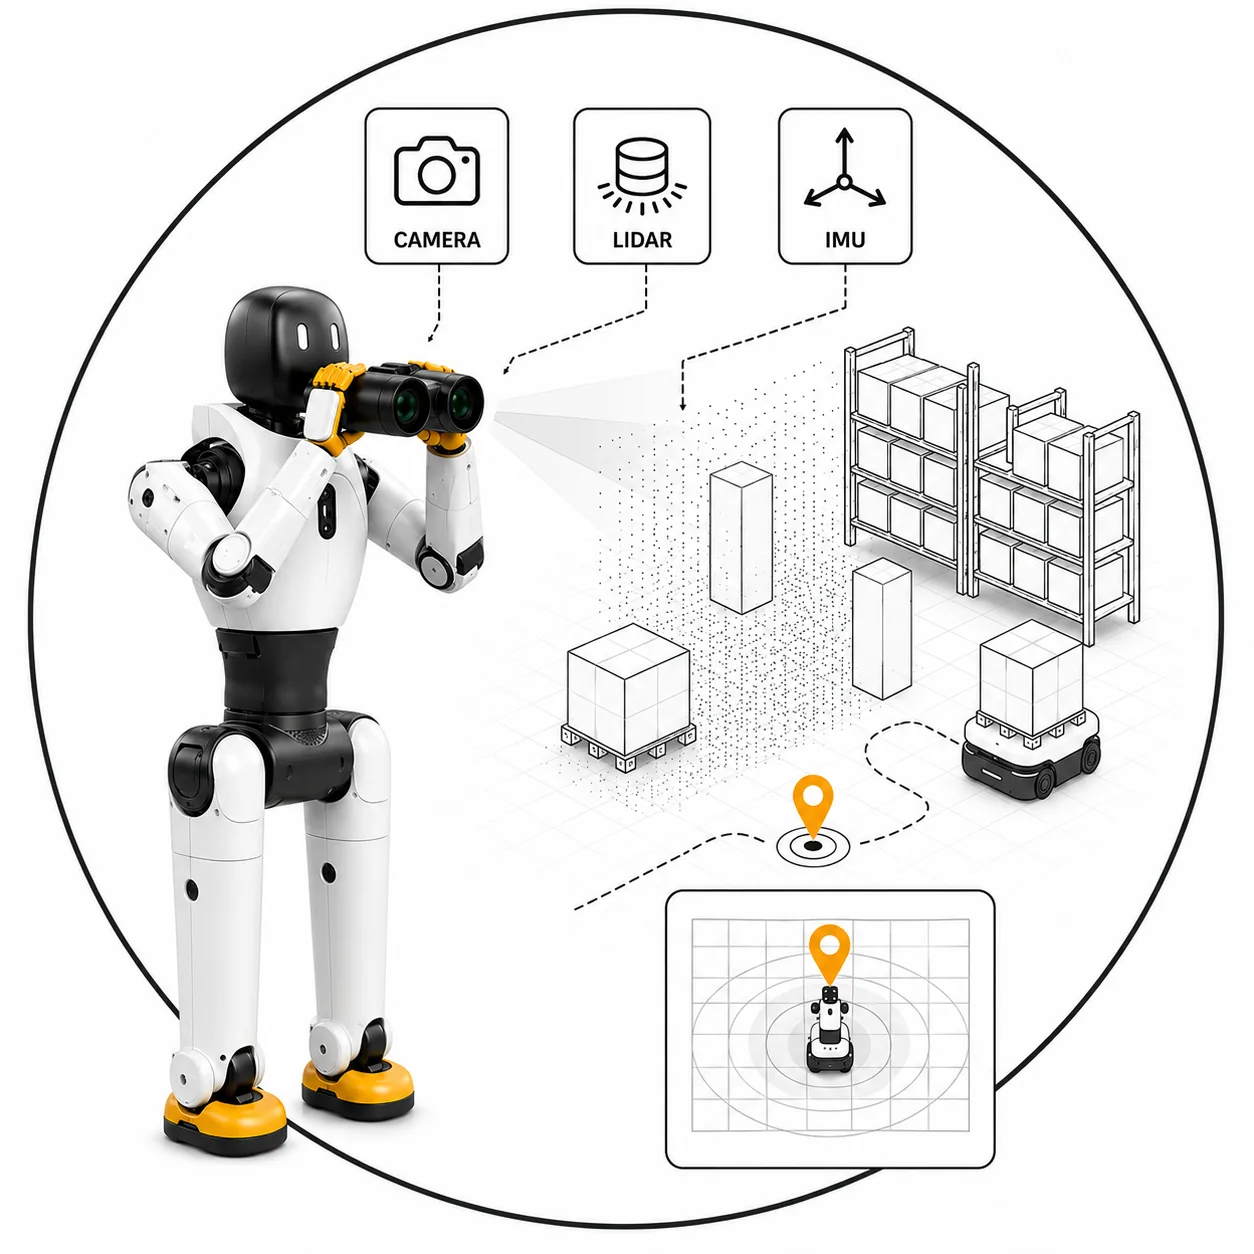
A white humanoid robot with yellow hands and feet holding binoculars to its face, a pale cone spreading from them across an isometric line drawing of a warehouse, under three labelled sensor icons and beside an inset map panel.

Perception & Localisation

Perception and localisation for humanoid and mobile platforms: recognise the part, know where the robot is, and keep both stable in a live environment.

View details