What it does
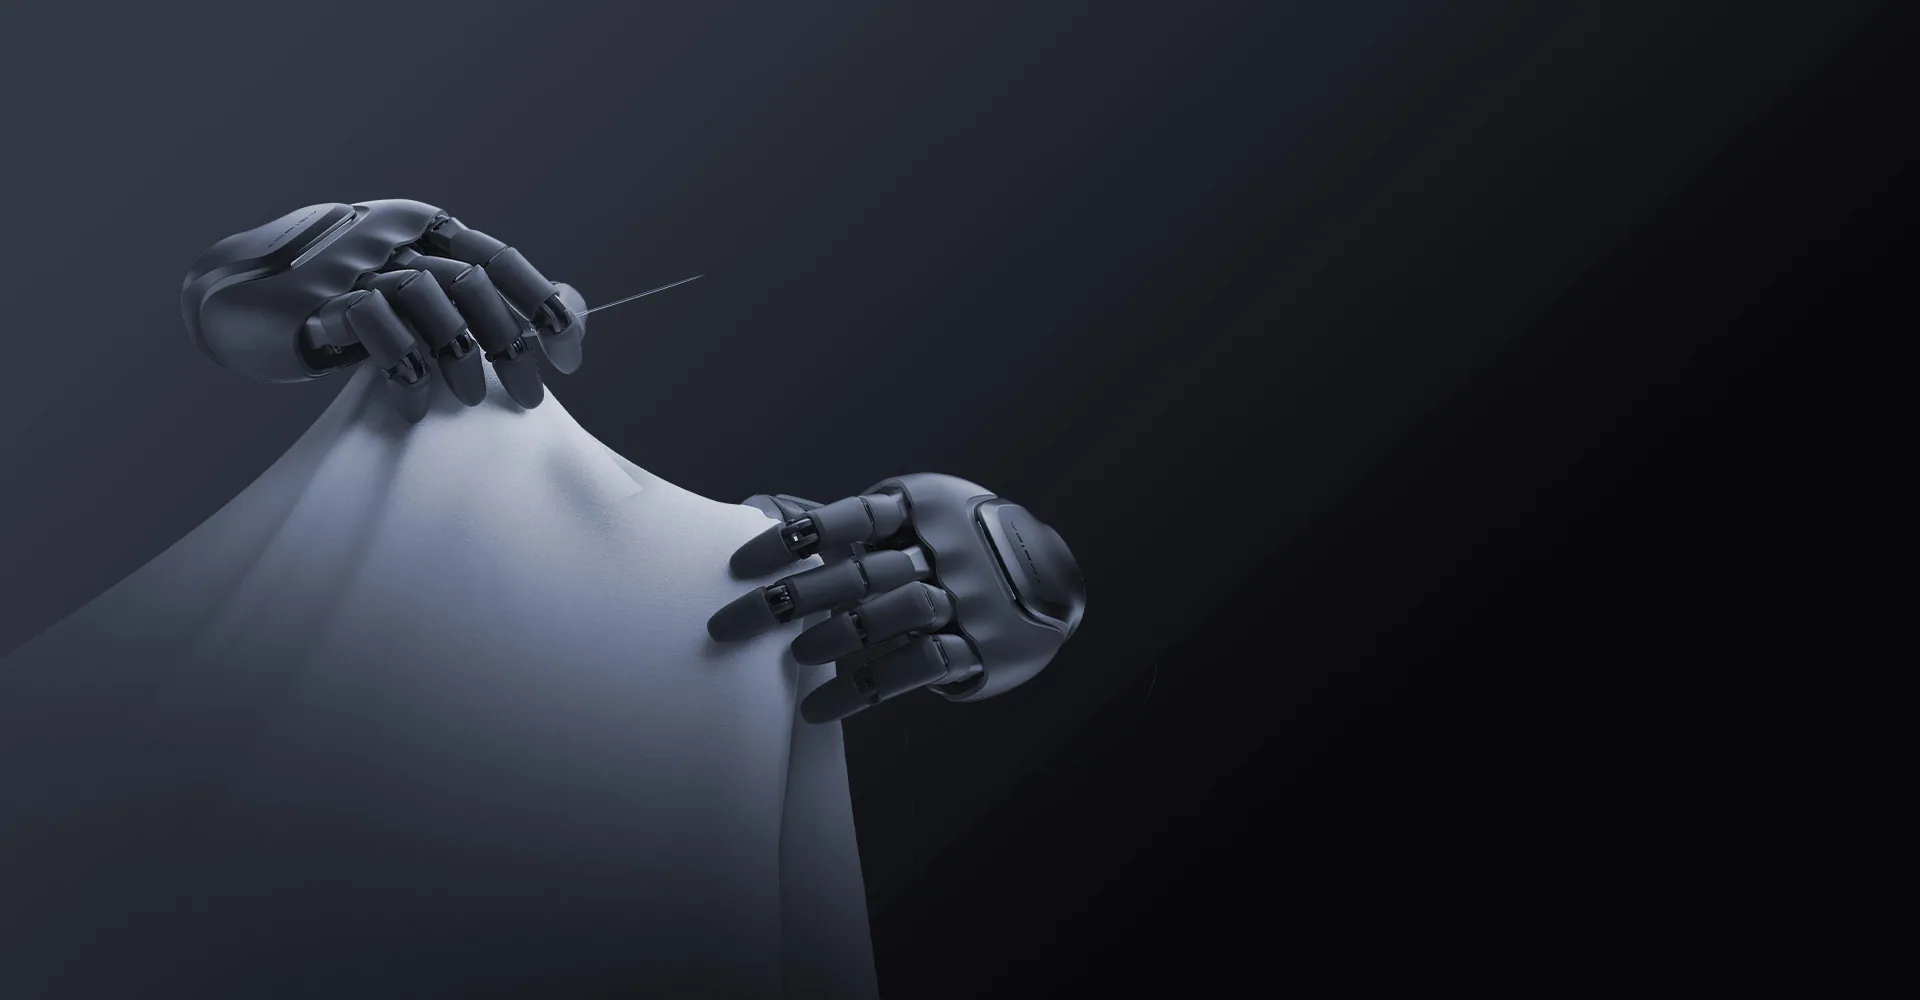
Photography and published figures from AGIBOT, the manufacturer of this model.
Human-sized, 12 active degrees of freedom
Built at the scale of a human hand, with the fingers driven individually. AGIBOT does not publish a weight figure for this hand.
Handles professional tools
A maximum fingertip force of 20 N in one hand, on a structure designed around gripping real tools.
Multi-modal sensing
Position, normal force, tangential force and proximity are sensed together and fed to the hand's control algorithms. AGIBOT does not publish a force-resolution figure.
Diagrams from the manufacturer
AGIBOT publishes these drawings in English. We show them exactly as published.
Software and SDK
- Licence
- Mulan PSL v2
Permissive licence: you may build on this commercially, provided you keep the licence and notices. Verified against the repository, not a marketing page.
The variants, and what changes
These trims share the base platform, so the useful comparison is not the full parameter table repeated for each one but the rows where each one says something different. Where a variant is a mirror-image build with an identical specification, there is nothing to tabulate and we say so instead of inventing a difference.
AGIBOT OmniHand Pro 2025 (left)
The left-hand unit of the OmniHand Pro 2025. Mirror-image build and identical specification to the right-hand version, where the full parameter table is listed. The Pro trim is the one to pair when the task needs the higher grip force on both sides.